What is a Drone
Unmanned Aerial Vehicles (UAVs), commonly called drones, are aircraft that fly without an onboard pilot. They range from palm-sized recreational quadcopters to long-endurance fixed-wing platforms used for surveillance, inspection, cargo delivery, and scientific research. What unites them all is a relentless engineering constraint: every gram of weight reduces performance, and the electric motor is the single heaviest and most efficiency-critical component in the propulsion system.
At Turncircles we develop coreless axial flux BLDC motors specifically to address this constraint — delivering more thrust per gram than any conventional brushless motor topology.
The modern drone is the product of converging advances in microelectronics, lightweight composite materials, battery chemistry, and electric motor design. Each generation of commercial UAV has pushed these components closer to their physical limits — and in each generation, the electric motor has emerged as the primary lever for extending endurance and payload capacity.
How a Drone Stays Airborne
All aerial vehicles generate lift by moving air. Fixed-wing drones use wing airfoils to create lower pressure above the wing than below it — the same principle as a manned aircraft. Multirotor drones achieve lift differently: each propeller is itself a rotating wing, accelerating air downward to generate upward thrust. The key insight is that lift is never free — it always requires energy, and the total energy available is bounded by the battery capacity.
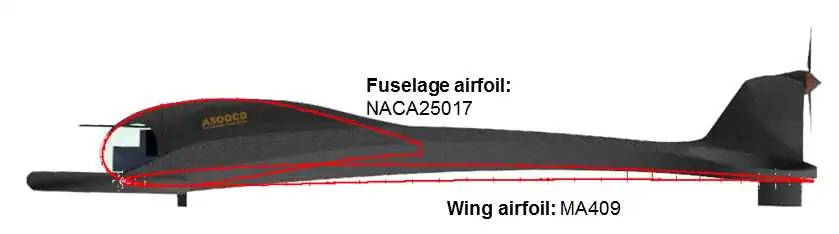
The four variables that govern how well a drone uses its available energy are: thrust (motor and propeller efficiency), aerodynamics (airframe drag and lift-to-drag ratio), structural weight (materials and design), and energy storage (battery or fuel energy density). Of these, motor efficiency and motor weight are the two factors that Turncircles directly improves through axial flux motor technology.
The Core Components of a UAV
Understanding the role of each subsystem helps explain where weight and efficiency losses accumulate — and where the biggest gains can be made.
-
Flight Controller
The brain of the system. It reads inertial sensors (accelerometer, gyroscope), GPS, and barometric altitude data, then issues commands to the motor speed controllers many times per second to maintain stable flight. More capable flight controllers can follow pre-programmed waypoints and execute fully autonomous missions. The quality of the flight controller affects stability and responsiveness, but its mass contribution is modest — typically under 50 g.
-
Electronic Speed Controllers (ESC)
Each motor is paired with an ESC that converts the flight controller's digital commands into precisely timed three-phase AC current. The ESC determines how efficiently the motor is driven: a poorly matched or low-quality ESC introduces switching losses that reduce overall system efficiency. Modern high-frequency ESCs paired with low-inductance axial flux motors deliver notably tighter speed regulation and lower heat dissipation than older designs.
-
Battery
Lithium polymer (LiPo) cells dominate UAV applications due to their high discharge rates and good energy density. The battery is usually the heaviest single component on a small drone, often representing 25–40% of total take-off weight. Because the motor converts battery energy into mechanical power, any improvement in motor efficiency directly reduces the battery capacity needed for a given mission — or equivalently, extends the mission duration on an unchanged battery.
-
Payload and Sensors
Most commercial UAVs carry some form of imaging payload: a visible-light camera, thermal infrared camera, multispectral sensor, or LiDAR unit mounted on a stabilised gimbal. The payload mass competes directly with battery mass in the weight budget. Reducing motor weight is therefore doubly valuable: it allows either more battery or more payload on the same airframe.
-
Electric Motors and Propellers
The motor converts electrical energy into mechanical rotation; the propeller converts rotation into thrust. Together they define the efficiency of the propulsion system and represent the largest mechanical mass on a multirotor. This is where axial flux technology delivers its most decisive advantage.
Why Electric Motor Weight Dominates Drone Performance
On a quadcopter, there are four motors. On a hexacopter, six. Each motor must not only produce thrust but carry itself aloft — and in doing so, consume a share of the battery that could otherwise extend flight time. The relationship is not linear: a heavier motor requires more thrust from all four motors to hover, which increases current draw, which drains the battery faster, which may require a heavier battery to compensate. Weight compounds.
Radial flux brushless motors — the conventional outrunner design used in the majority of commercially available drones — have a cylindrical geometry where the stator core is surrounded by a rotating outer shell. The iron laminations in the stator that are necessary for magnetic flux concentration also add significant weight and generate core losses at all operating speeds. The active parts of a typical radial flux motor producing 200 W continuous might weigh 180–300 g.

Axial flux motors place the stator disc between two rotor discs with opposing permanent magnets. The magnetic flux travels axially — along the motor's rotation axis — rather than radially. This geometry naturally produces a flat, disc-like form factor with a high torque-to-weight ratio. Our coreless variant removes the iron stator entirely, replacing it with epoxy-embedded windings. The result is a motor whose active parts produce equivalent thrust at 80–120 g — less than half the active-part weight of a comparable radial flux design.
Axial Flux Motors: Performance at Every Throttle Setting
Motor efficiency is not a single number — it varies with load. A motor that achieves 90% efficiency at full throttle may drop to 70% efficiency at the cruise throttle settings used for most of a mission. Iron-core motors suffer from core losses that are present at all speeds regardless of load: hysteresis losses increase with frequency (RPM), and eddy current losses increase with frequency squared. At the partial-load cruise points that define real-world endurance, these fixed losses are disproportionately costly.
Coreless axial flux motors have no iron, so they have no core losses of any kind. Losses arise only from copper resistance (winding I²R losses) and bearing friction. This means the efficiency curve remains flat across a wide throttle range, keeping the motor near peak efficiency whether climbing, cruising, or holding position in wind.

The Scalable Axial Flux Motor Platform
One of the practical advantages of the axial flux topology is that it scales well across a wide power range without changing the fundamental architecture. Increasing the motor diameter raises torque; adjusting the winding configuration changes the voltage and current characteristics; stacking multiple rotor-stator pairs multiplies power output. All of these variations retain the coreless construction, the flat form factor, and the weight advantage.
This scalability matters to UAV designers because the motor selection problem changes significantly between a 250 g inspection drone and a 25 kg cargo platform. Turncircles motors span this range, from sub-100 W units for micro UAVs to multi-kilowatt motors for heavy-lift and VTOL cargo applications.

The Practical Impact: More Flight Time, More Payload
The commercial UAV market is converging on a small set of hard requirements: operators want to fly longer, carry more, and spend less time on the ground between missions. Battery energy density is improving slowly — roughly 3–5% per year for lithium chemistry. Motor efficiency and weight, by contrast, can be improved dramatically through a change in motor topology, without waiting for new materials or chemistry.
Moving from a conventional radial flux motor to a Turncircles coreless axial flux motor on a quadcopter platform typically yields 20–30% longer hover endurance on the same battery, or alternatively allows the same flight time with a payload increase of equivalent mass to the weight saved per motor. For a four-motor platform saving 100 g per motor, that is 400 g of additional payload capacity — enough for a high-resolution thermal camera, an upgraded GPS antenna, or additional battery mass to further extend range.
For drone operators, designers, and integrators looking to push the performance envelope of their platforms, the electric motor is the most direct path to improvement. Understanding what a drone is also means understanding what limits it — and what can be done about it.
Explore Custom Axial Flux Motors
Custom High-Efficiency Electric Motor Design
Why only a motor designed around the exact application delivers efficiency at application level.
Lightweight Axial Flux Electric Motors
Torque per gram, PCB and DCB stators, and naked or wet motors that save housing weight.
Axial Flux vs Radial Flux Motors
An engineering comparison of the two topologies: power density, thermal behaviour and application fit.
Application Concepts
Concept studies for drones, VTOL cargo aircraft and space vehicles built around axial flux motors.
Design your axial flux motor
Use the Turncircles configurator to set your thrust, voltage, and weight requirements and receive a simulation-backed motor specification — in minutes.
Configure your motor